
2023
Distributed Traffic Control
Fault-tolerant traffic-light control with reinforcement learning agents that coordinate over gRPC, so the grid keeps working when some agents fail.
Open-source tools, systems and competition work. For papers and reports, see Research.
Fault-tolerant traffic-light control with reinforcement learning agents that coordinate over gRPC, so the grid keeps working when some agents fail.
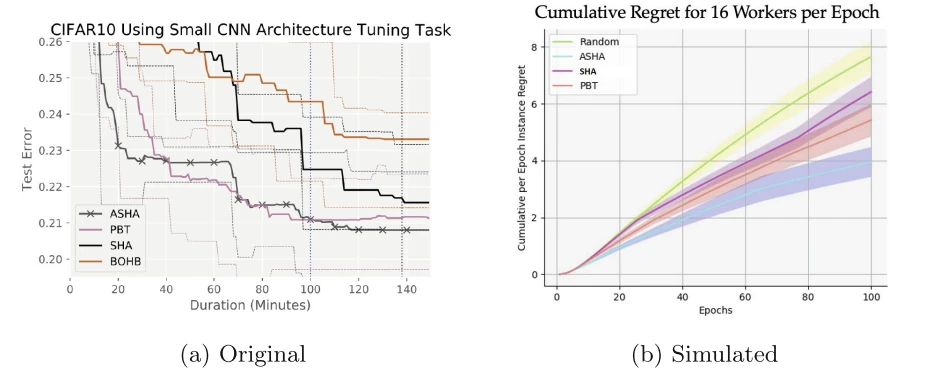

Hyperparameter tuning with cross-validation built in, on top of Ray Train. Schedules jobs by fold and model configuration.
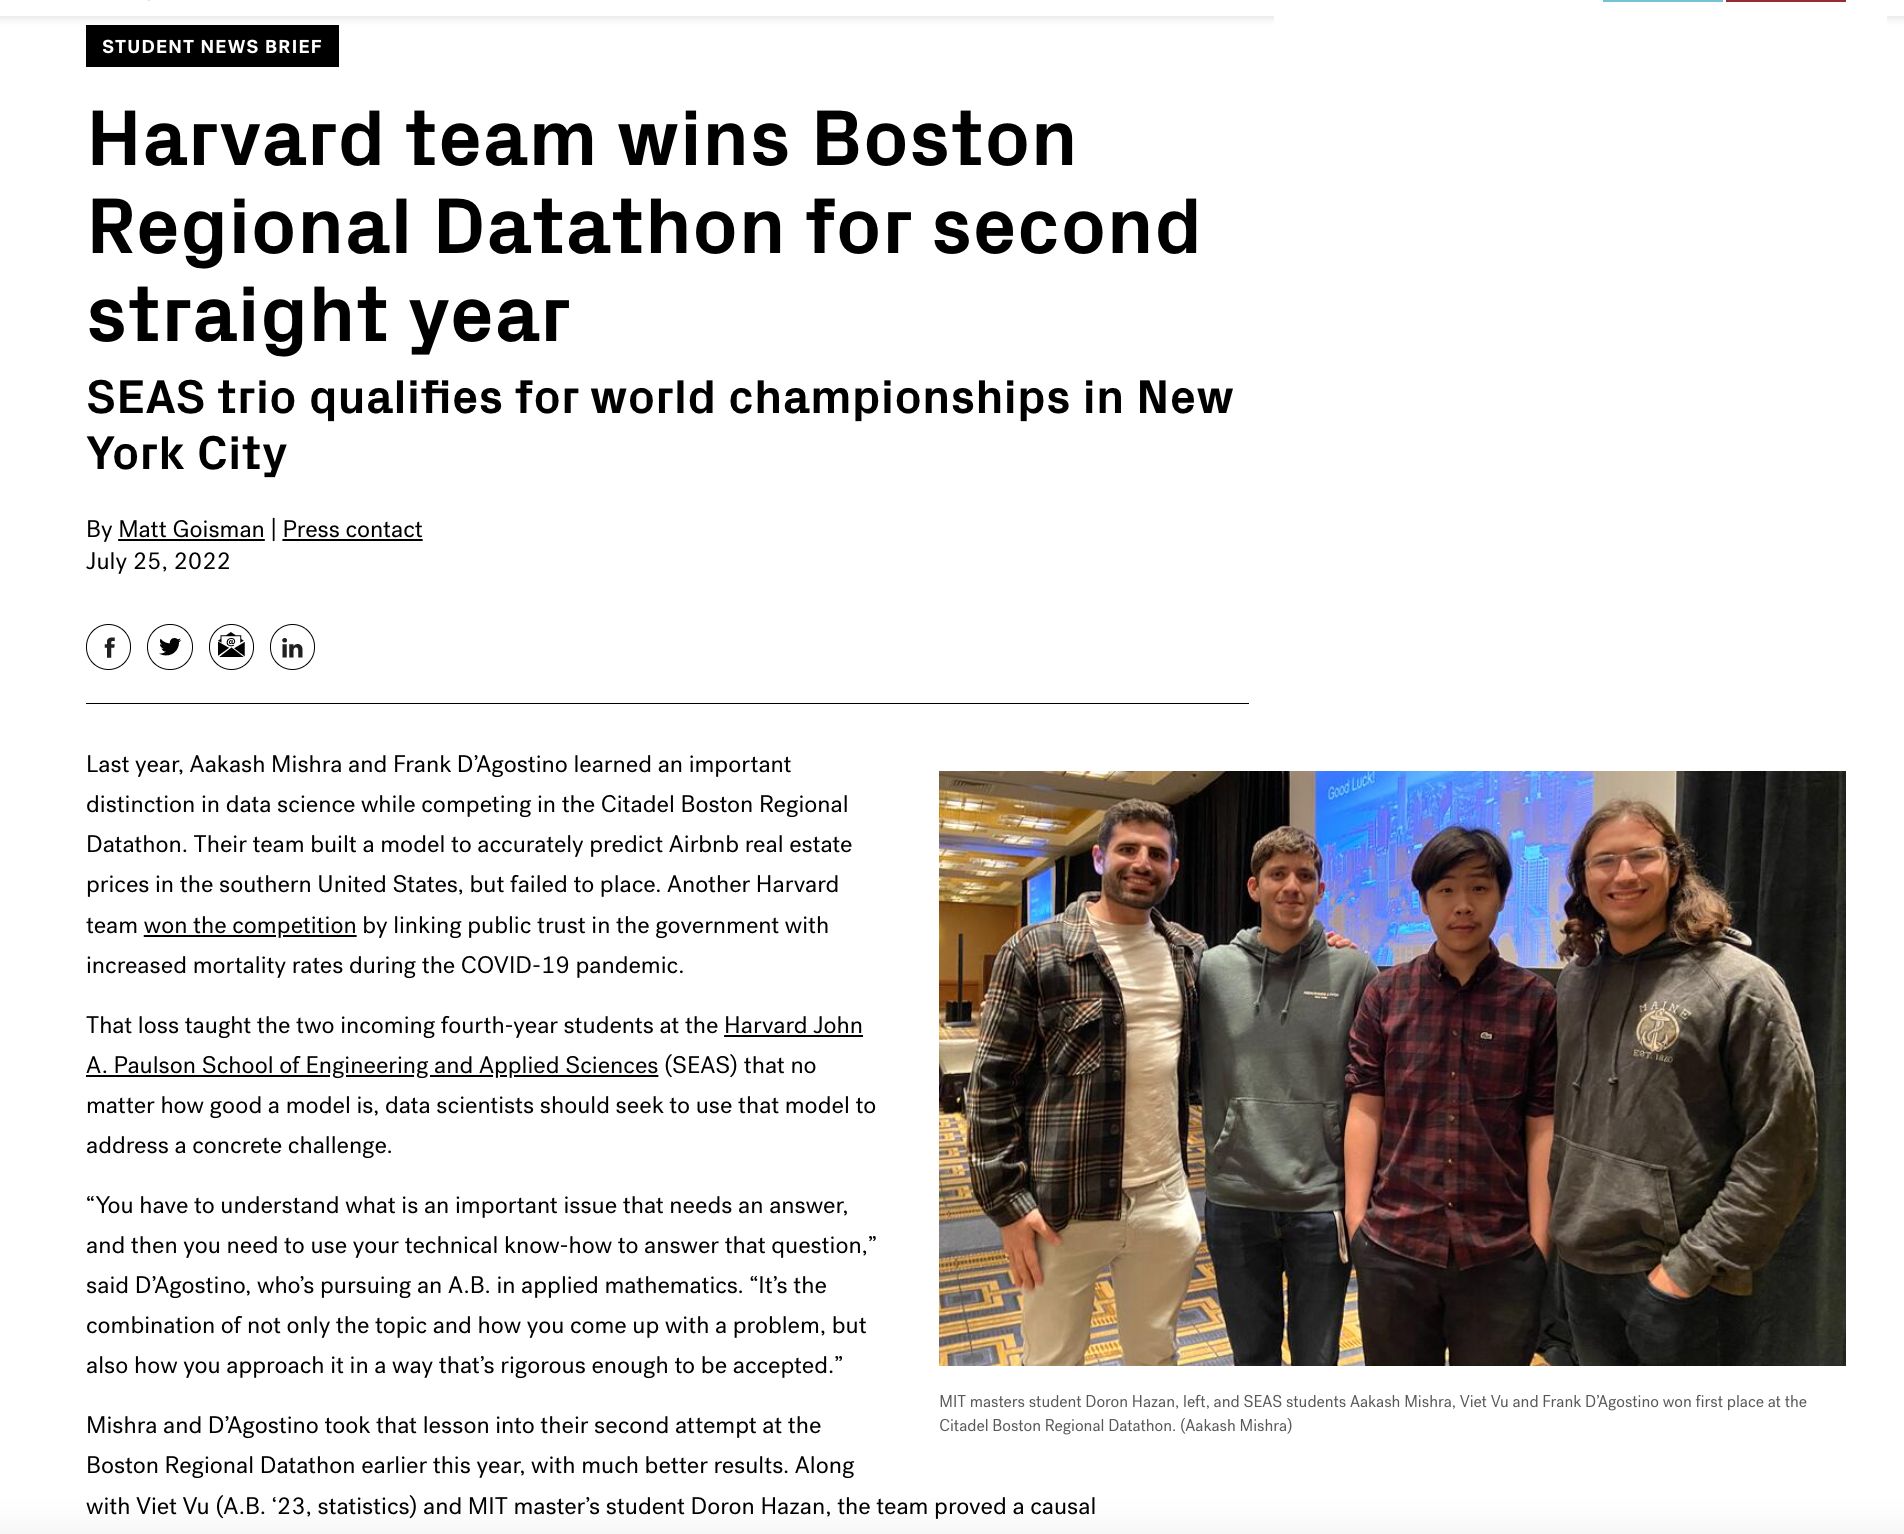
A k-nearest-neighbors take on synthetic control over 70,000 NIH patient records. Showed a causal effect of glipizide on heart failure outcomes and won first place.

Robot soccer players that combine control, vision and strategy. I led the team and wrote both firmware and high-level strategy code.
A Ray-based all-reduce implementation of PowerSGD, the low-rank gradient compression method for distributed training.
An automatic differentiation library for differential-equation matrices written as text or LaTeX, usable from C++ and Python.
Turns pandas DataFrames into LaTeX table code.